Trust in Human-Robot Teams
How people and autonomous robots come to trust each other when they work as a team, studied in controlled virtual environments.
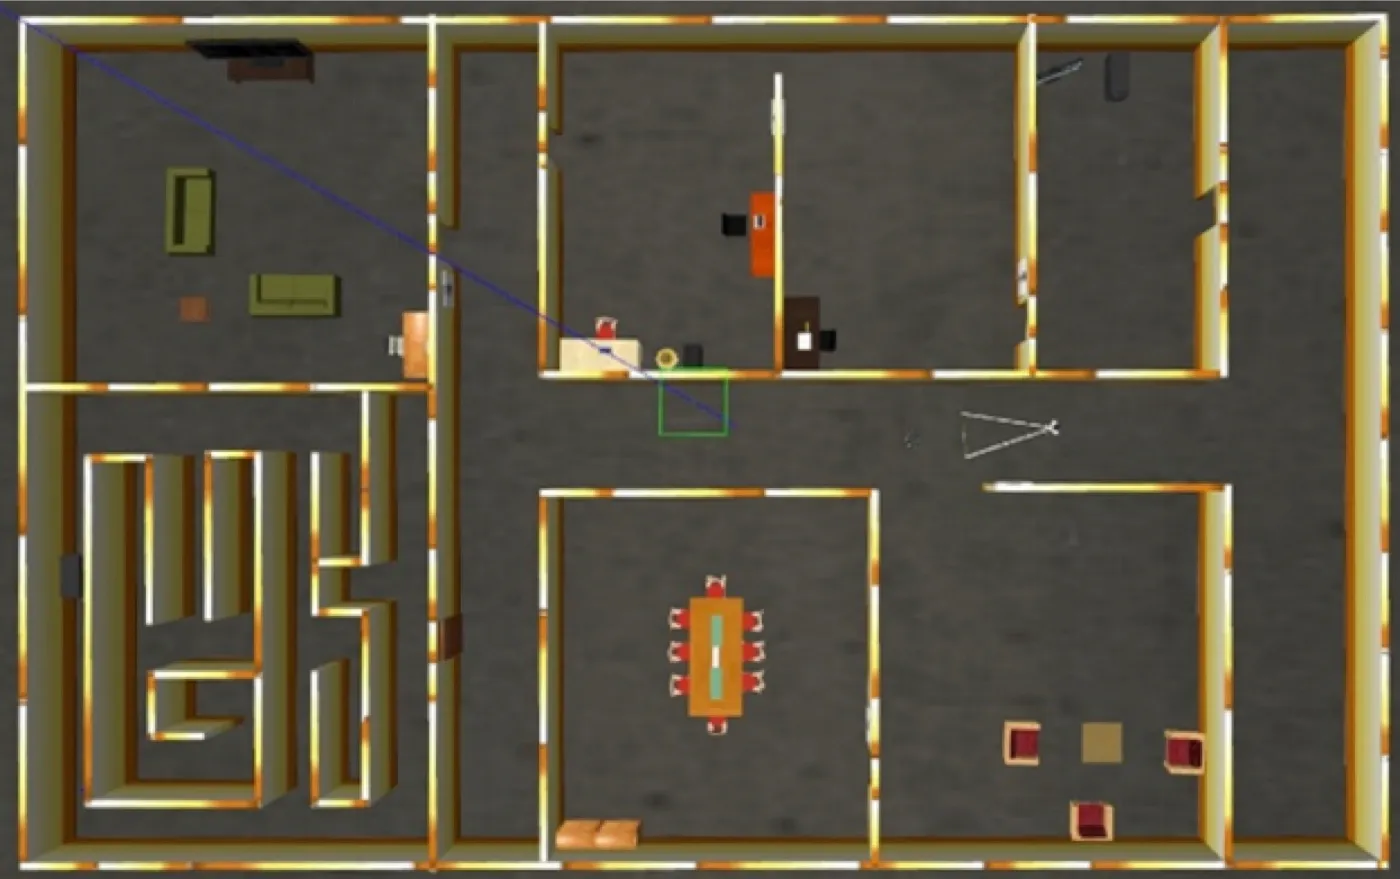
As robots take on more autonomous roles, teams of people and robots have to decide how much to rely on each other. This project, with Prashant Doshi’s lab, Neal Outland and colleagues in the Terry College of Business, studies how that trust forms and changes. It was part of the U.S. Army DEVCOM Analysis Center’s research program on AI and autonomy, through Northeastern University.
The team built a controlled virtual testbed in which a person and an autonomous robot partner work through a multi-step mission together in a shared building, which lets researchers measure trust, monitoring and performance as the collaboration unfolds (IEEE CogMI 2024). On the robot’s side, a computational framework models a robot’s trust in its human teammates, so robots can decide when to rely on people (IEEE ICRA 2025).
Publications
- A Novel Computational Framework of Robot Trust for Human-Robot Teams B. Nare, J. Frericks, A. Challa, P. Doshi, K. Johnsen. IEEE International Conference on Robotics and Automation (ICRA 2025), 2025.
- Trust and Collaboration Testing in Controlled Human-Robot Environments J. Frericks, B. Kang, N. Outland, P. Doshi, K. Johnsen, A. Schecter. IEEE International Conference on Cognitive Machine Intelligence (CogMI 2024), 2024.