Point cloud teleoperation paper at ACM SUI 2026
Our study of real-time point clouds for quadruped robot teleoperation was presented at the ACM Symposium on Spatial User Interaction in Bari, Italy.
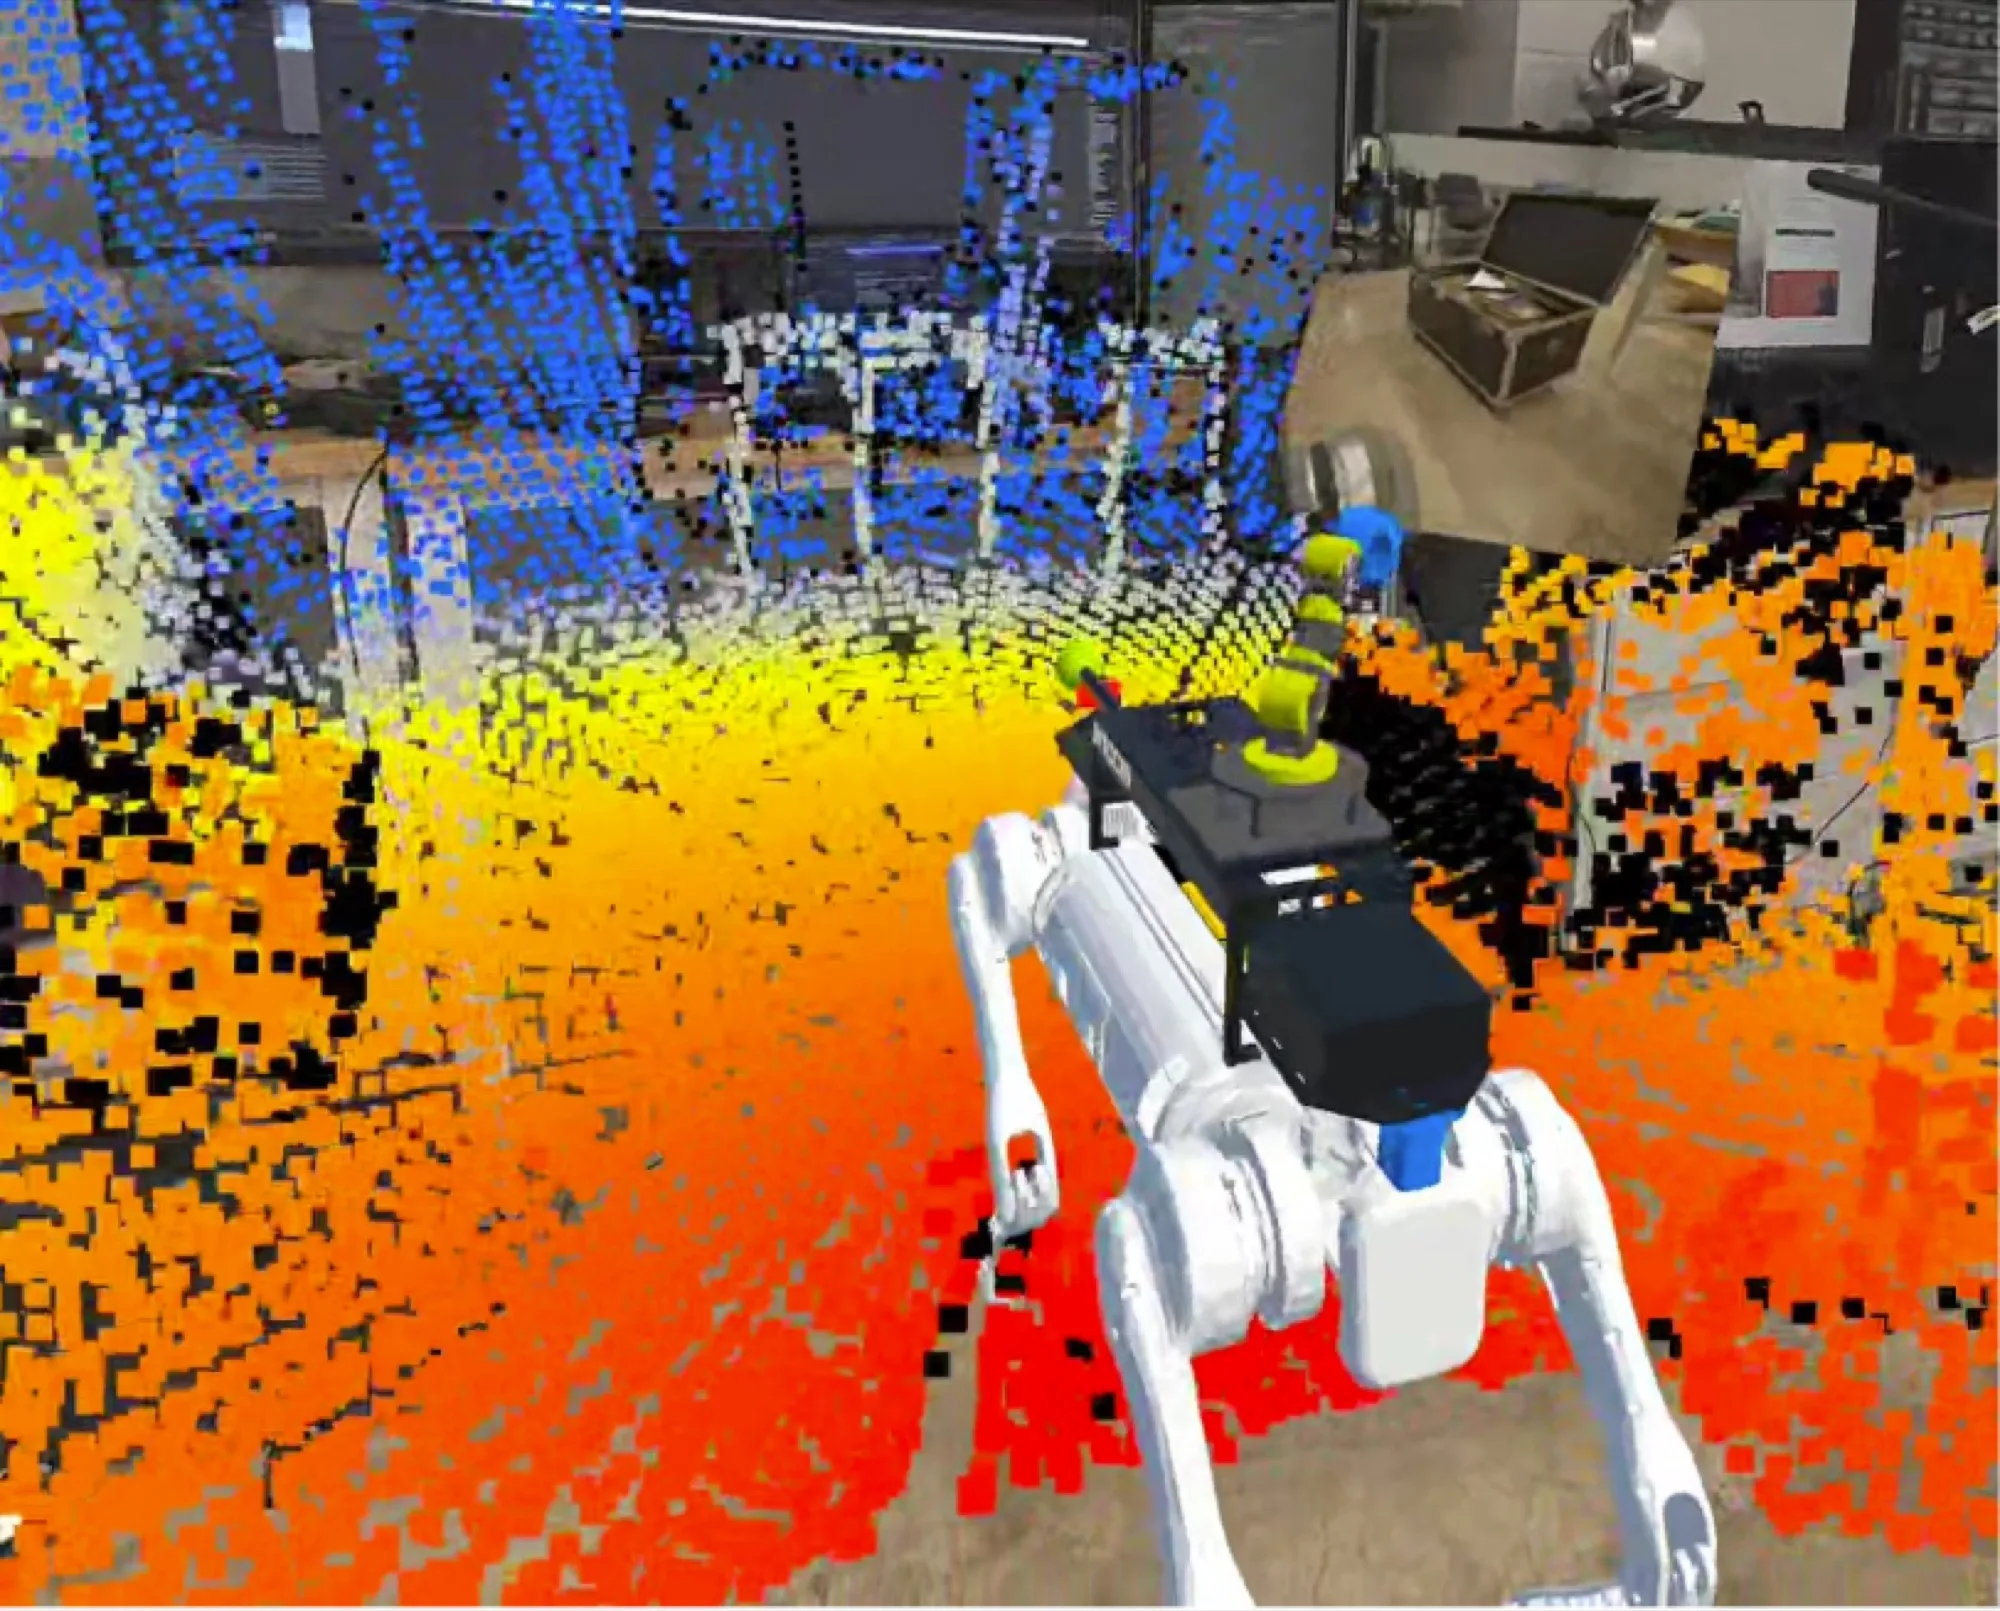
Our paper “Evaluating Real-time Point Cloud Visualization in Quadrupedal Robot Teleoperation” by Jordan Smothers, Andrew Rukangu and Kyle Johnsen was accepted for oral presentation at ACM SUI 2026 and is now in the ACM Digital Library (open access).
With a live point cloud of the robot’s surroundings, operators relied on the arm camera about a third less, and 13 of 14 preferred it. Read more about RobotCommand XR.