RobotCommand XR
Teleoperating a quadruped robot through mixed reality, with a live 3D point cloud of what the robot sees.
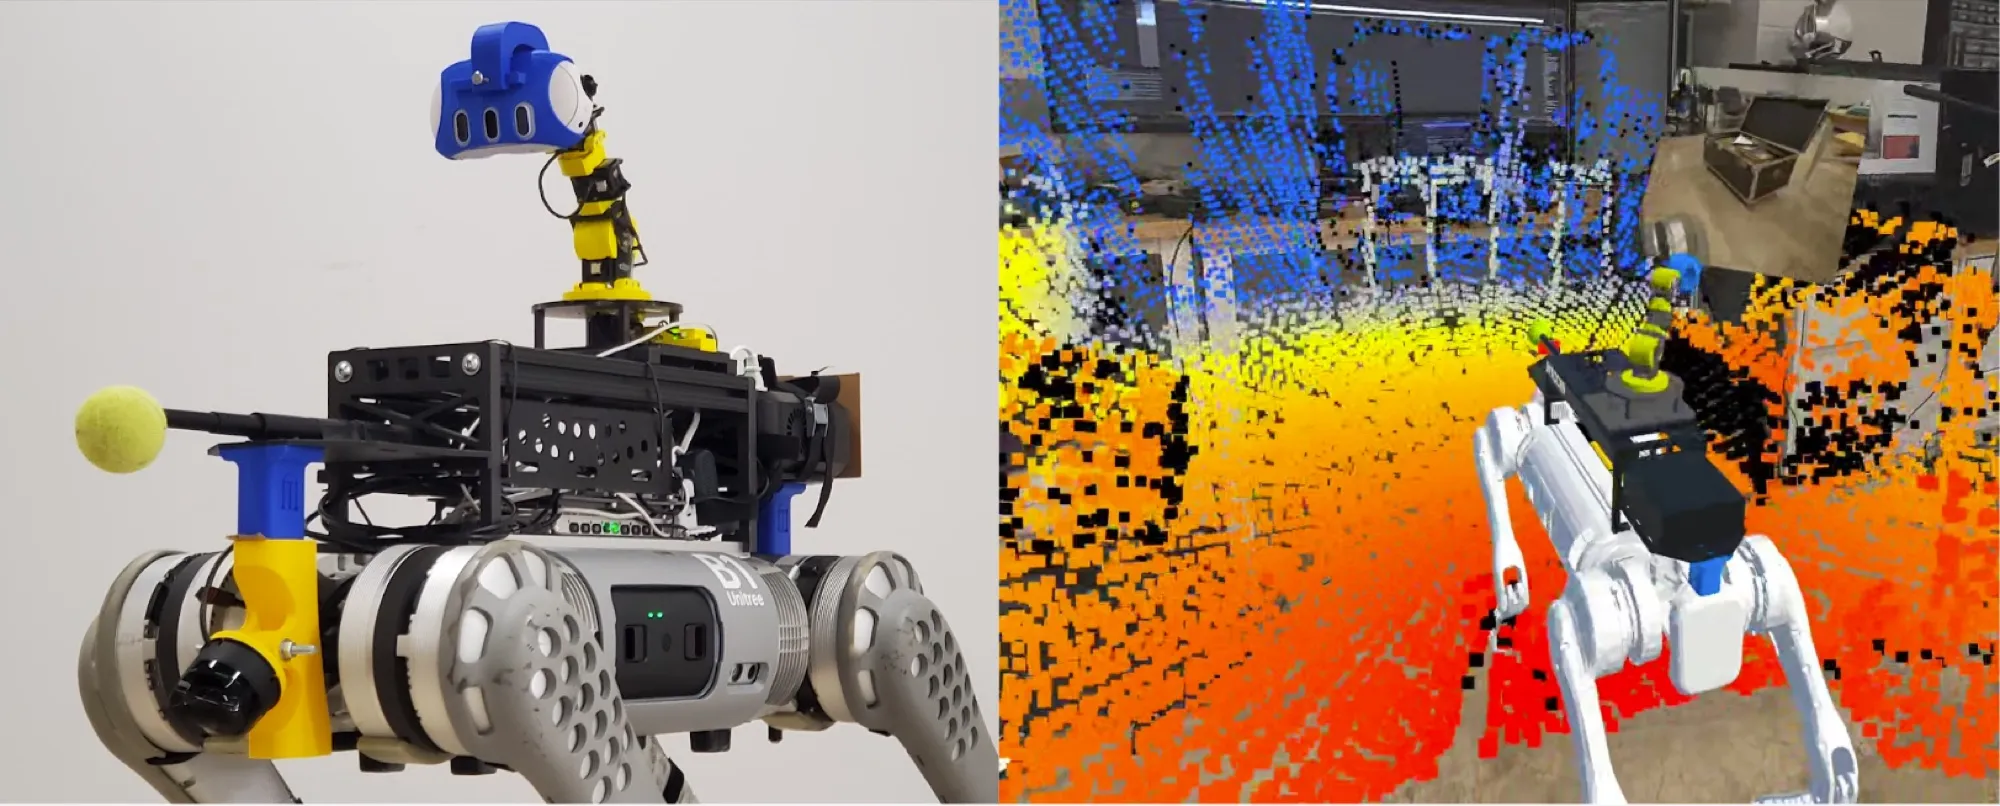
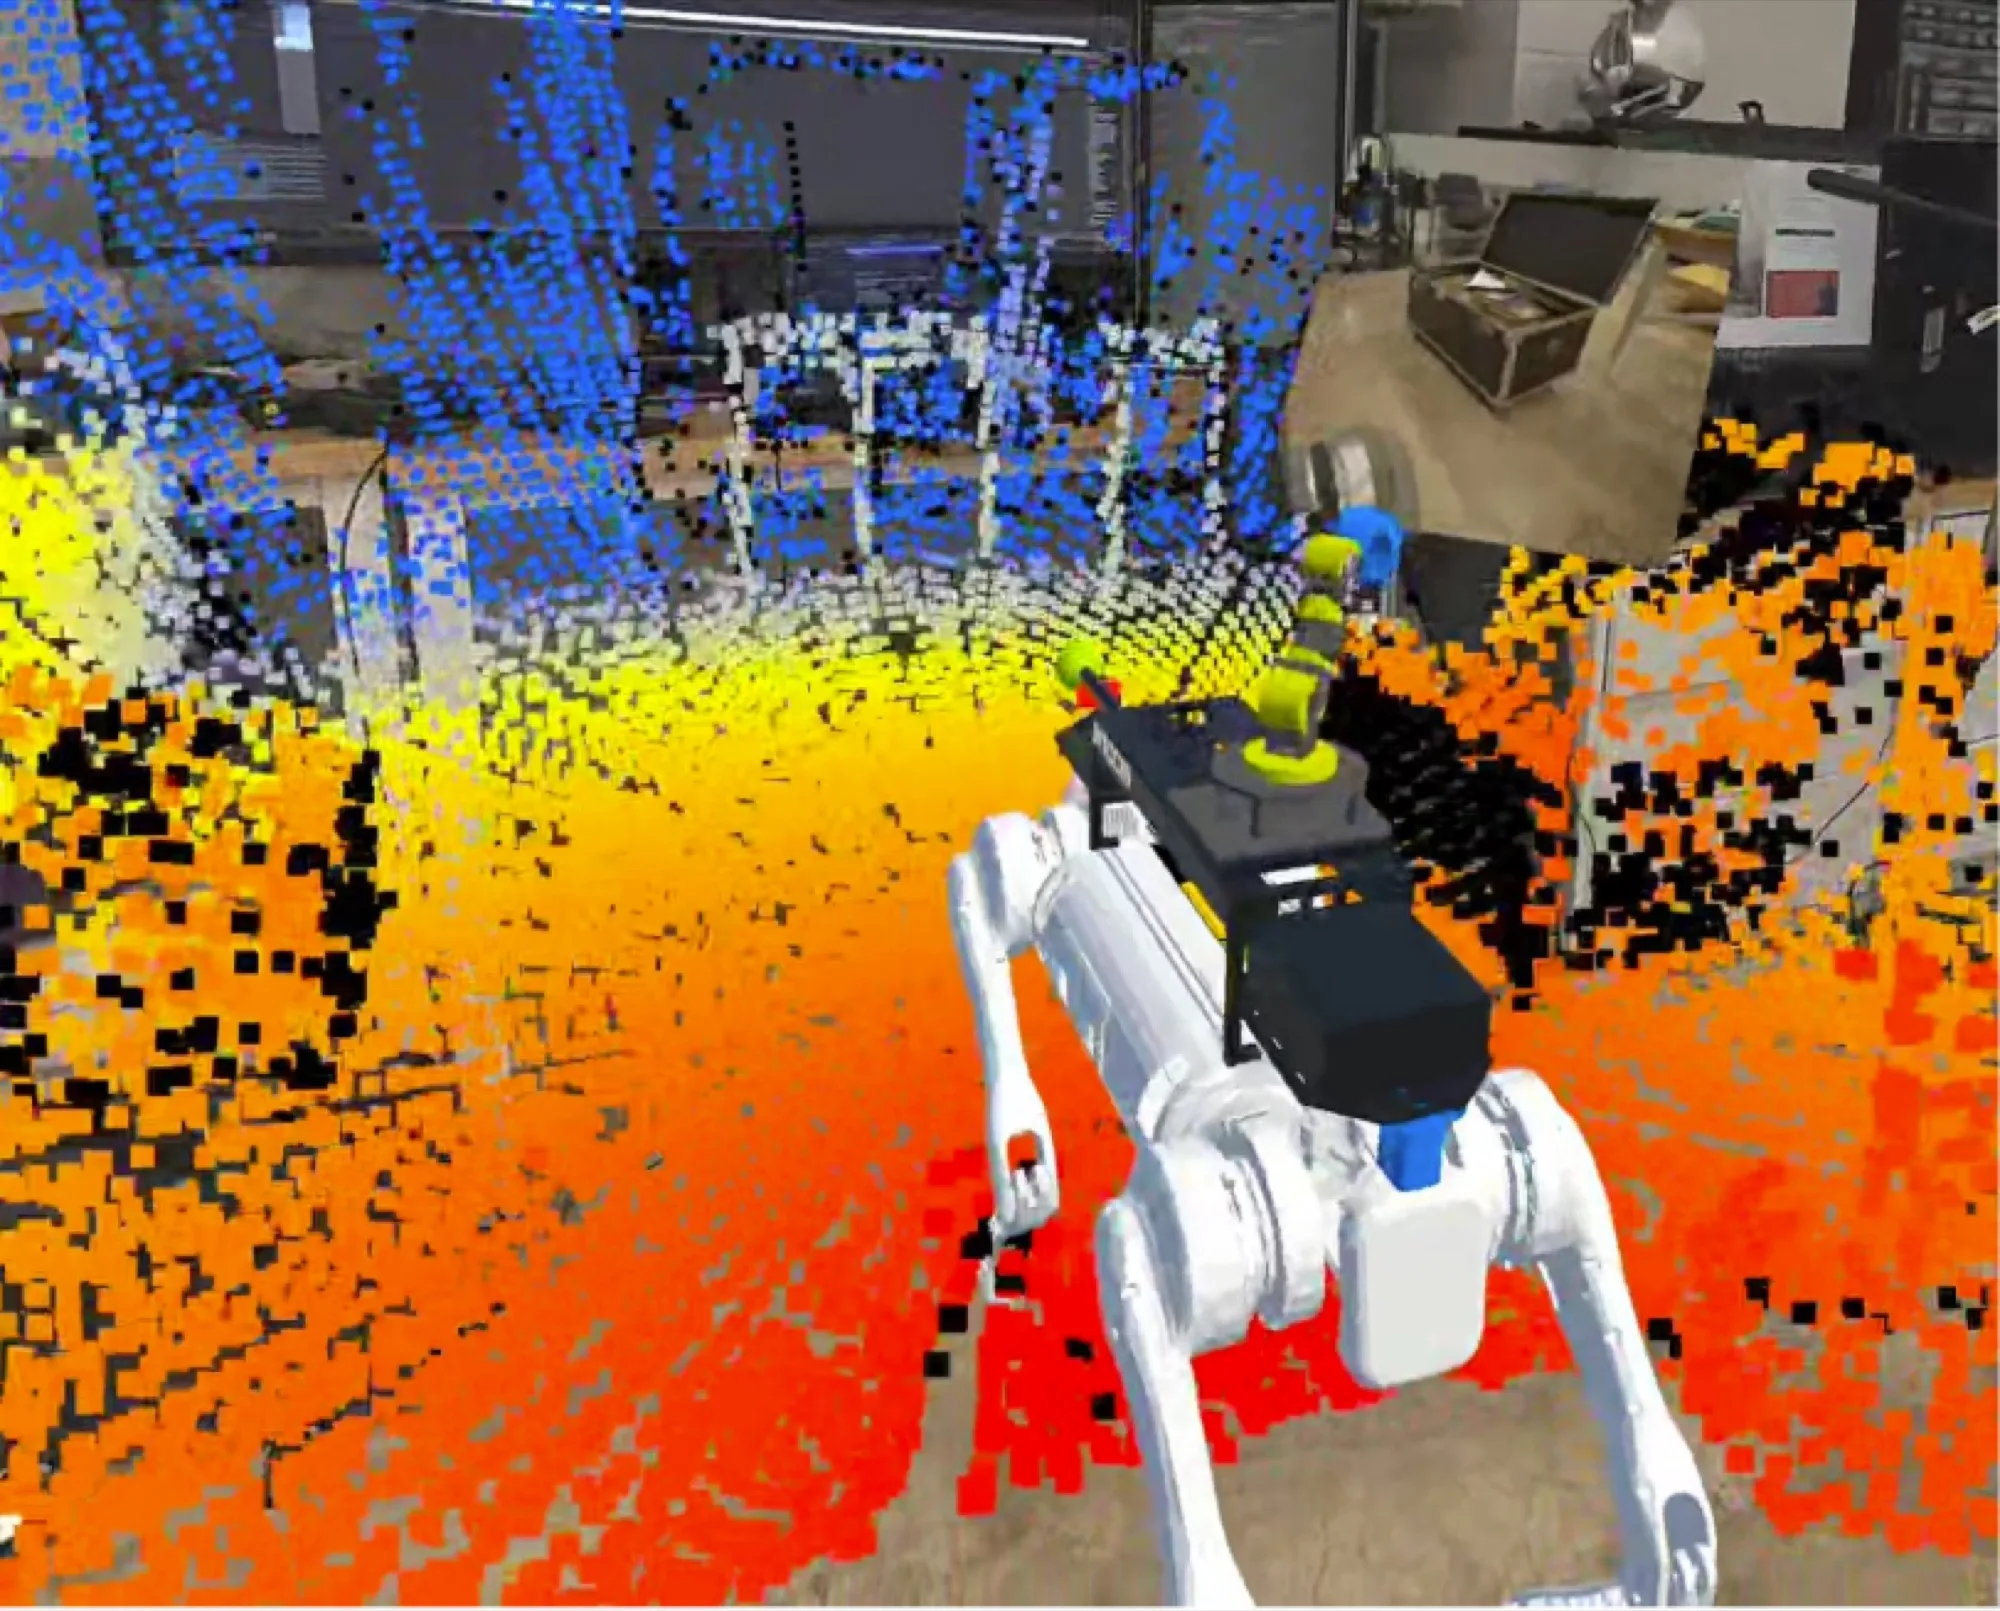
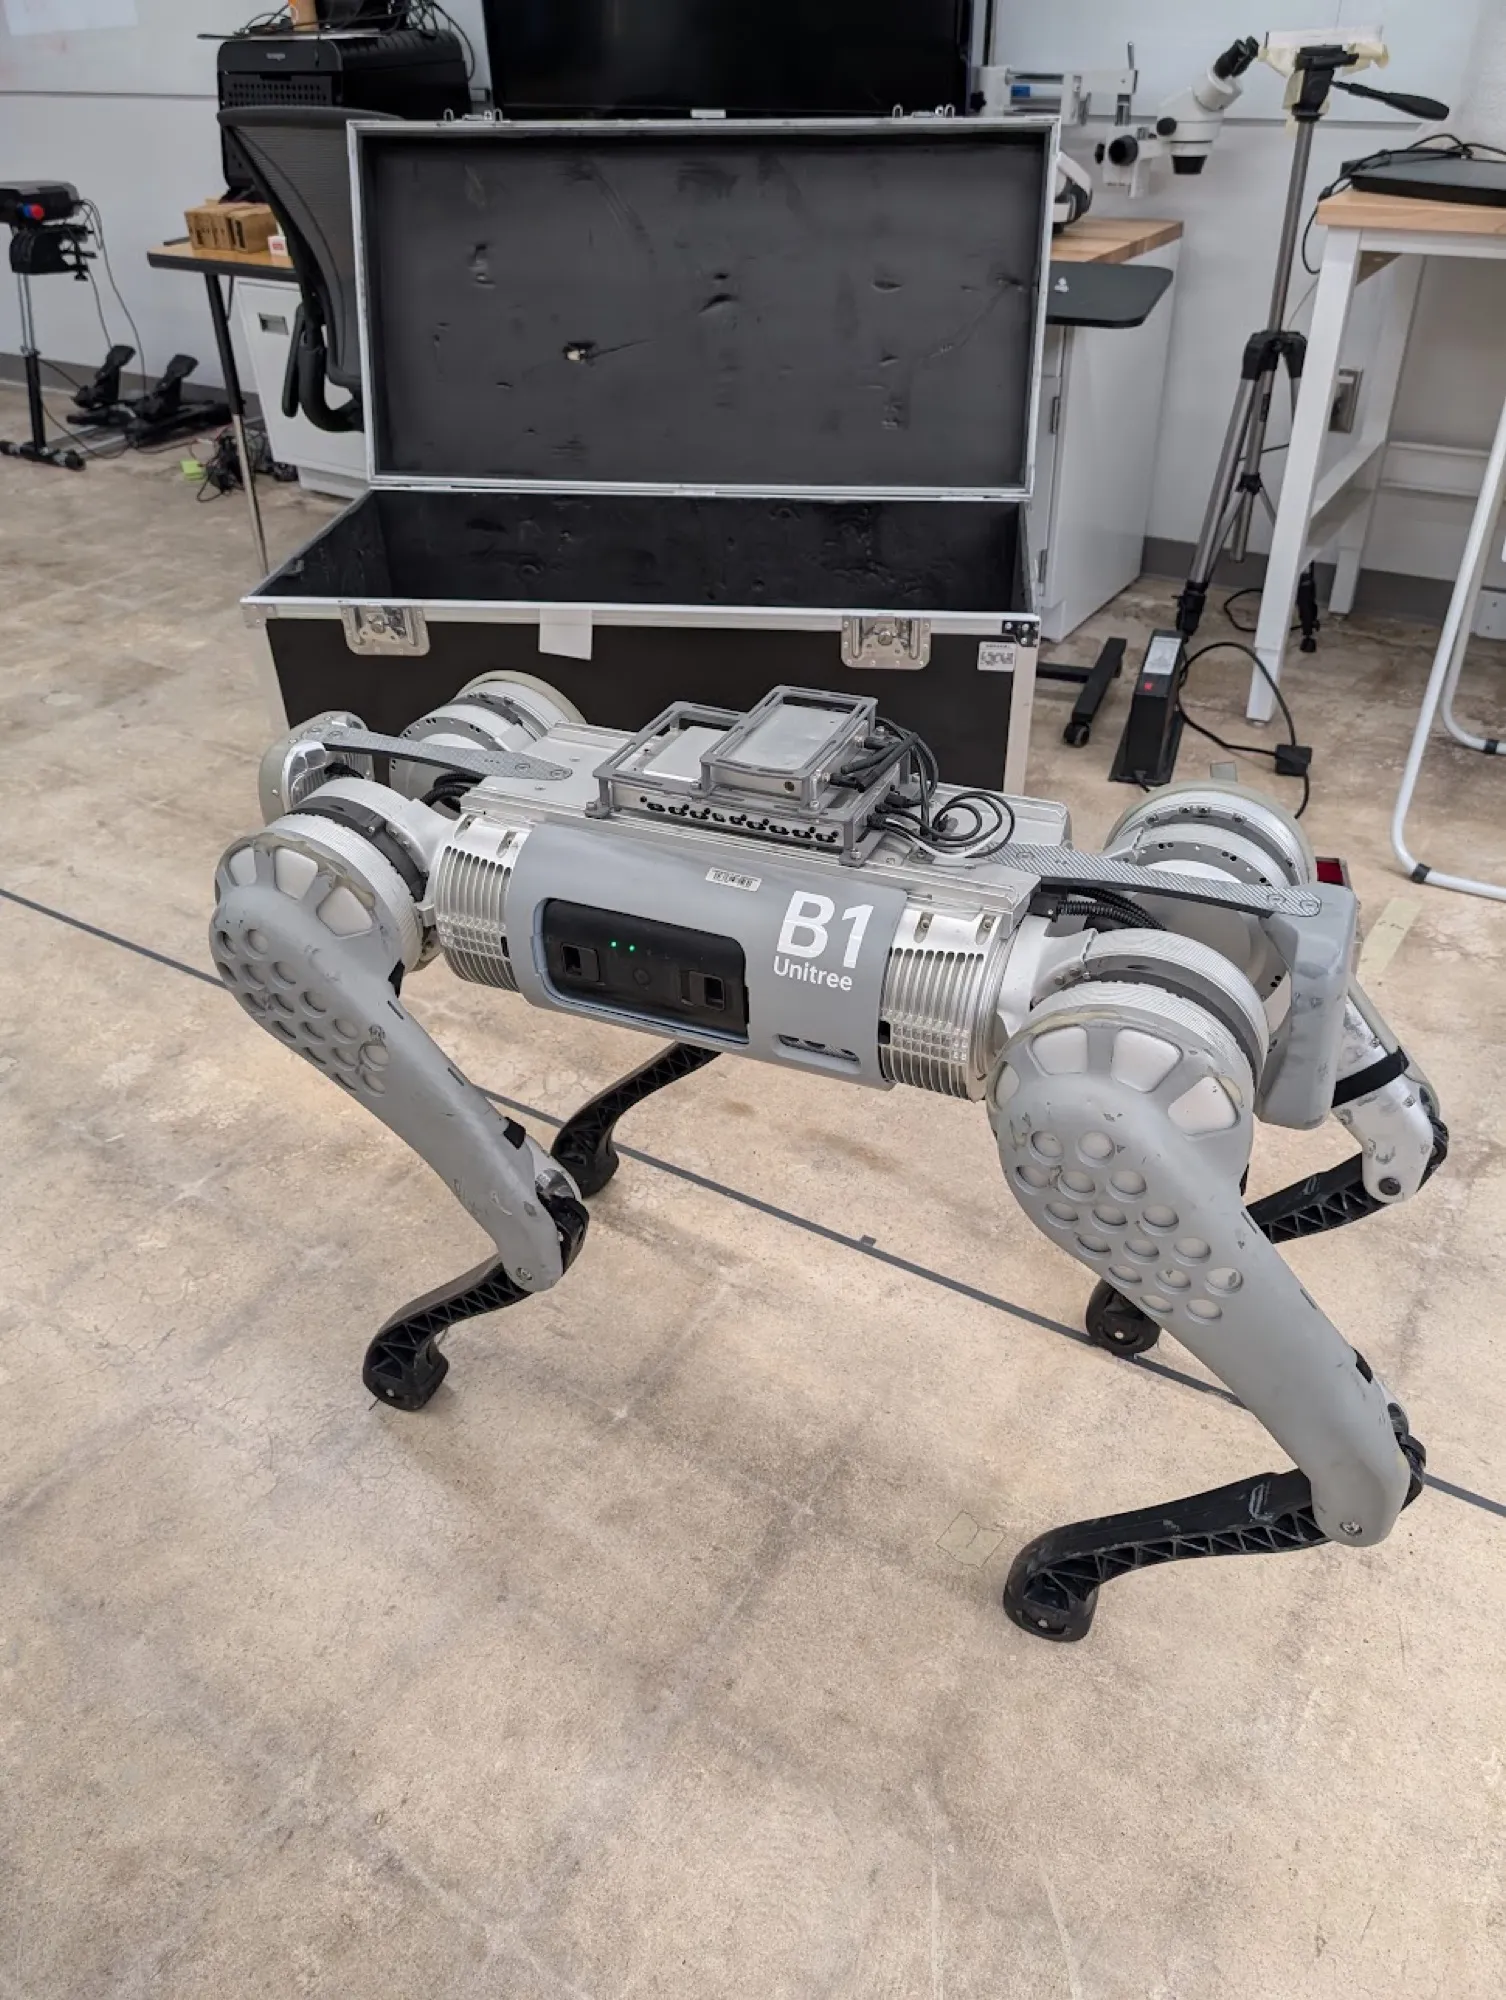
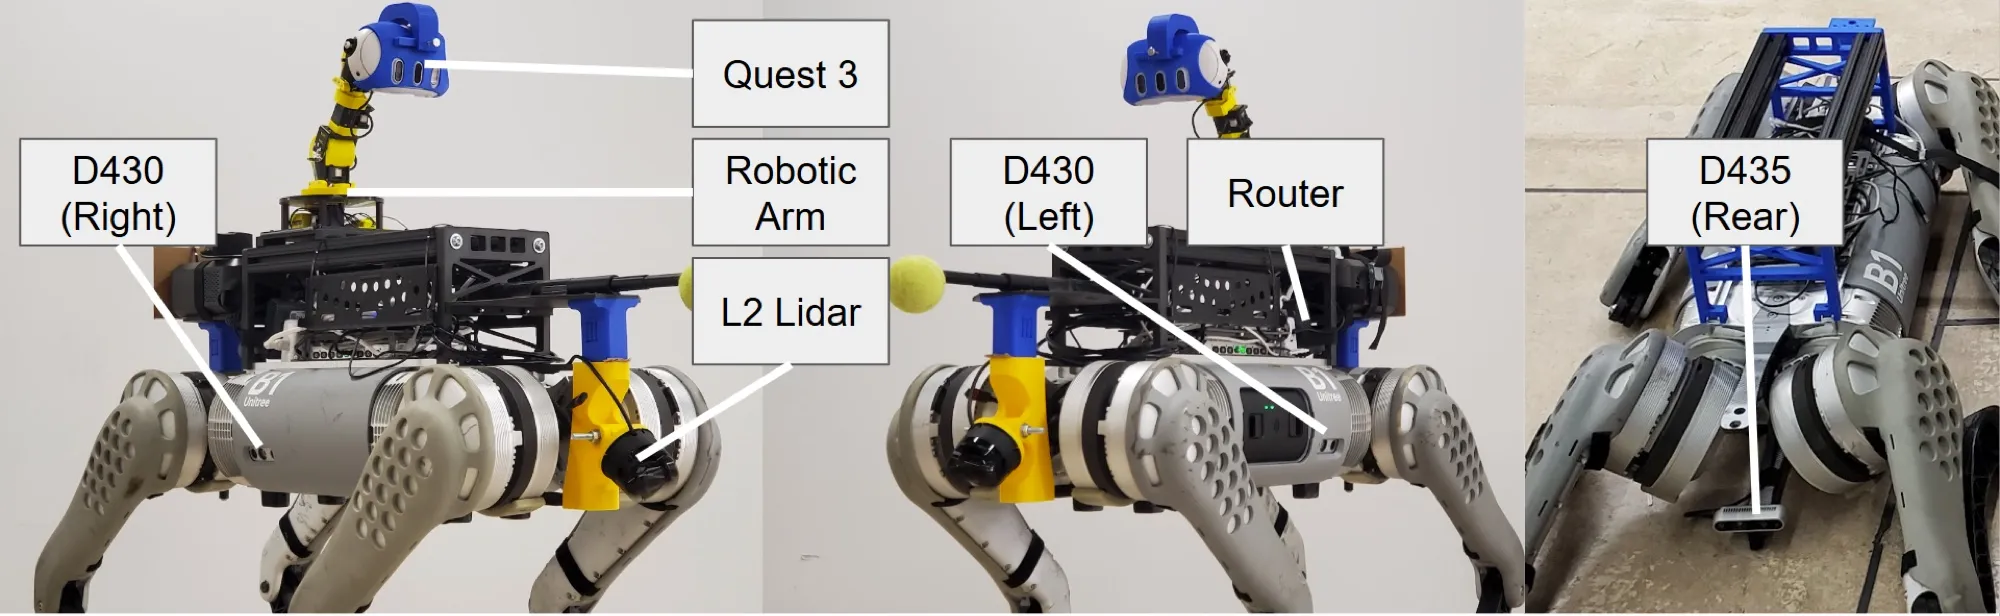
How do you give a remote operator a good sense of where a legged robot is and what is around it? RobotCommand XR (RCXR) answers with mixed reality. A Unitree B1 quadruped carries a lidar, depth cameras, and a Meta Quest 3 on a robotic arm that fuses the sensor streams. The operator, wearing their own Quest 3, sees stereo video, a miniature animated replica of the robot, and a live point cloud of the surroundings.
In our ACM SUI 2026 study, 14 participants teleoperated the robot with and without the real-time point cloud. With the point cloud, operators needed the arm camera about a third less often (105 s vs. 160 s), and 13 of 14 preferred it, even though they rated it as more demanding.
Publications
- Evaluating Real-time Point Cloud Visualization in Quadrupedal Robot Teleoperation J. Smothers, A. Rukangu, K. Johnsen. ACM Symposium on Spatial User Interaction (SUI '26), 2026.
In the news
Point cloud teleoperation paper at ACM SUI 2026
Our study of real-time point clouds for quadruped robot teleoperation was presented at the ACM Symposium on Spatial User Interaction in Bari, Italy.
Invited talk at the CPS Innovation Symposium
Kyle Johnsen spoke about teleoperating quadruped robots through mixed reality at the 2026 CPS Innovation Symposium at the Georgia Cyber Center in Augusta.
Jordan Smothers receives a CURO Research Award
Undergraduate researcher Jordan Smothers received a Fall 2026 CURO Research Award from UGA's Center for Undergraduate Research Opportunities.